ABOUT
Category
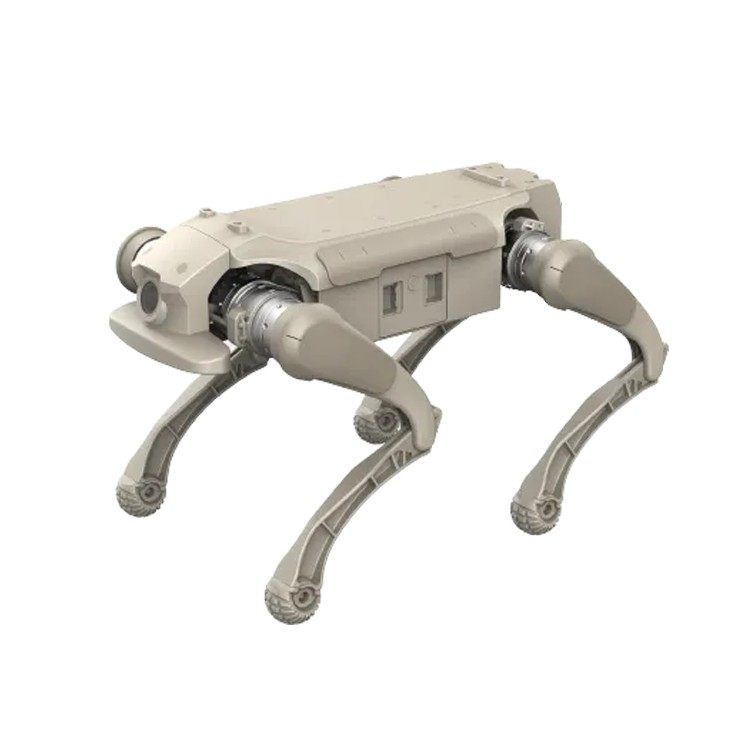
Gangbeng L1
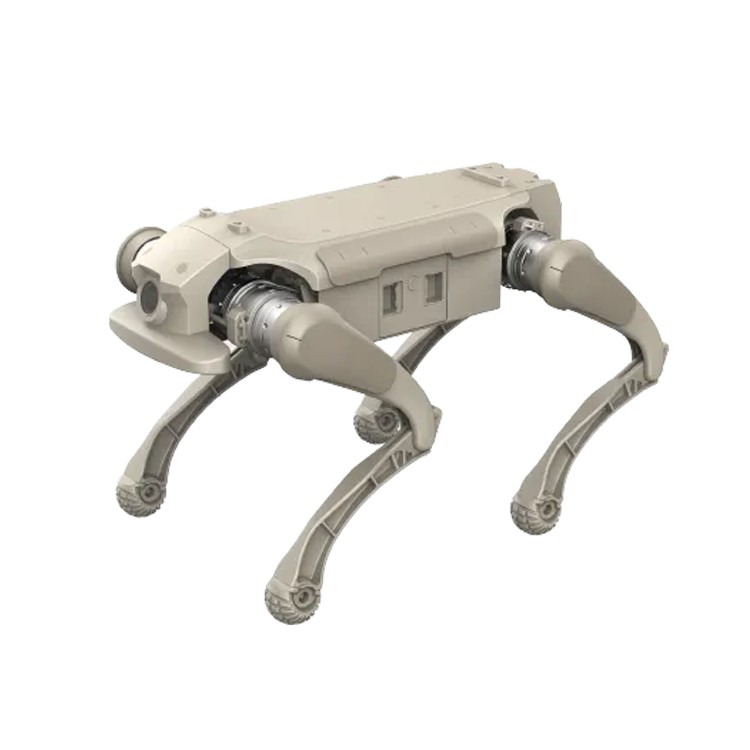
The bionic quadruped robot ZSL-1 features 12 degrees of freedom and supports a variety of locomotion gaits and movements. Meanwhile, this product provides an open SDK for motion control algorithm development and communication protocol, enabling users to conduct secondary development as required.
Detail
Product Overview
The bionic quadruped robot ZSL-1 features 12 degrees of freedom and supports a variety of locomotion gaits and movements. Meanwhile, this product provides an open SDK for motion control algorithm development and communication protocol, enabling users to conduct secondary development as required.
Download
Previous:EG2 Servo Electric Gripper
Next:T170A
Inquiry