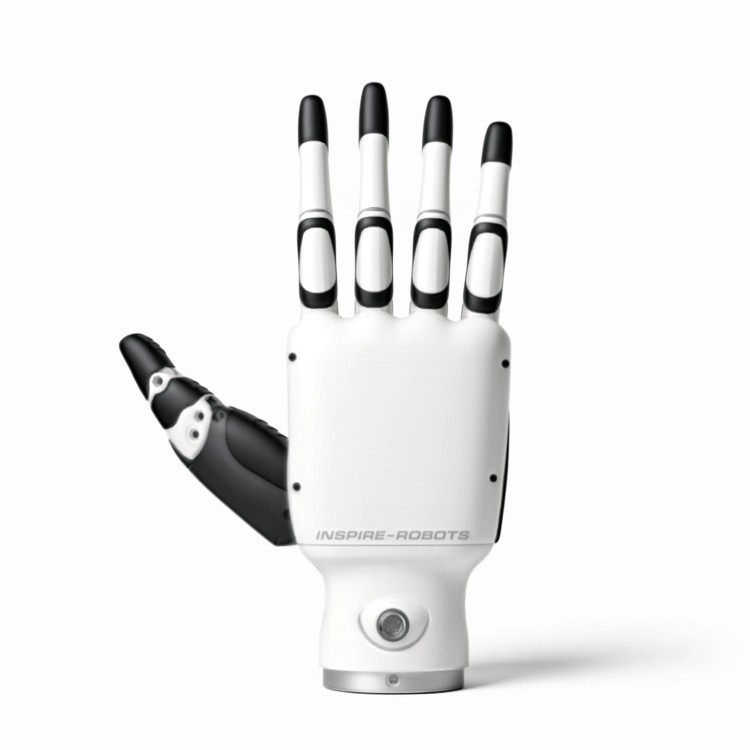
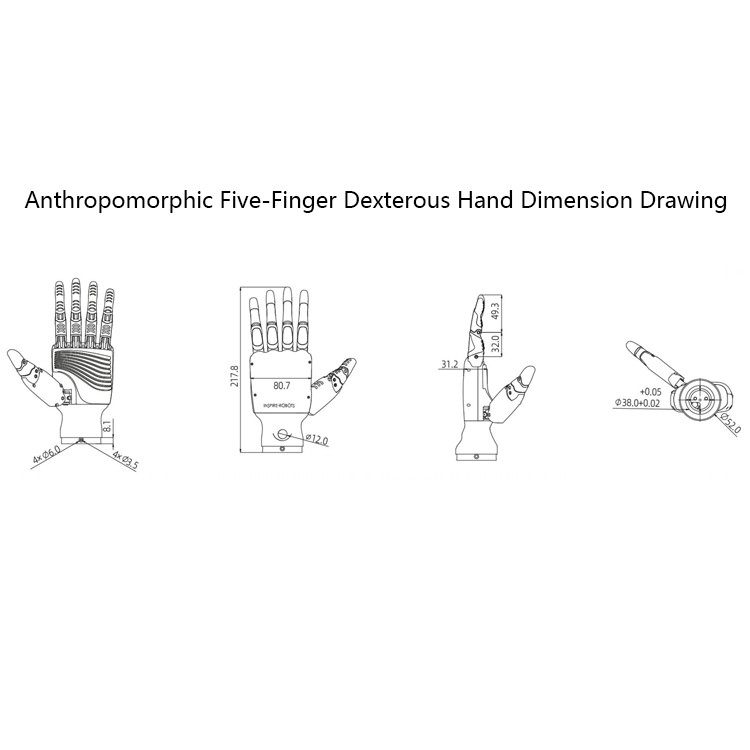
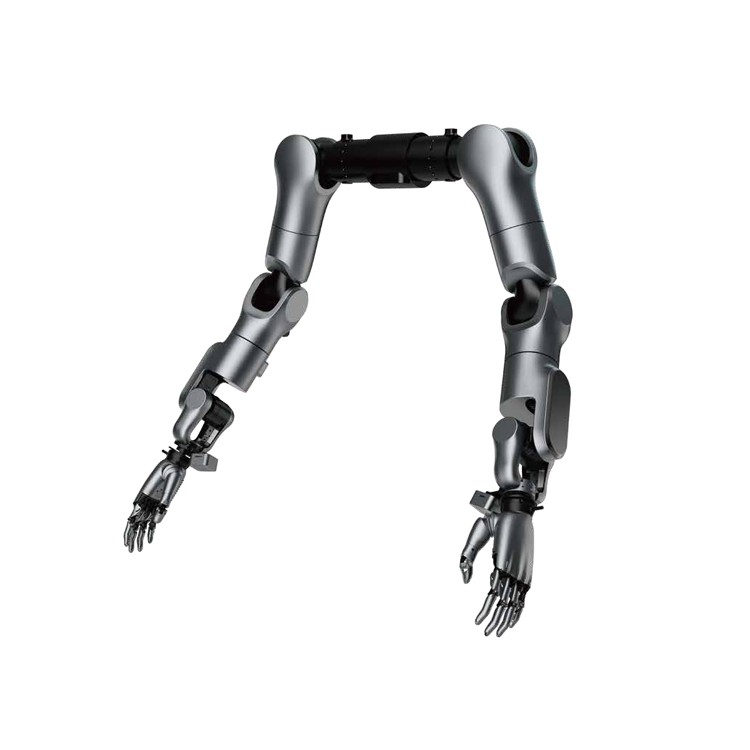
| RH56DFX Series · Humanoid Five-Finger Dexterous Hand |
|
|
|
| Standard / Wrist Version |
| Parameter | RH56DFX-2L (Left-hand model)
RH56DFX-2R (Right-hand model) | RH56DFXW-2L (Left-hand model)
RH56DFXW-2R (Right-hand model) |
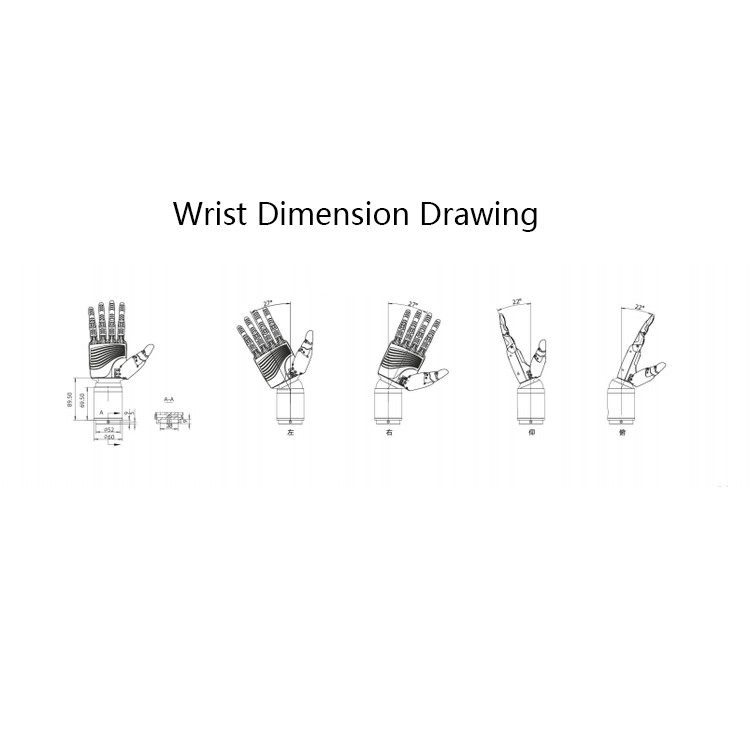
| Wrist | No | Yes |
| Control Interface | RS485 | RS485 |
| Degrees of Freedom (DOF) | 6 | 6+2 |
| Finger Joints | 12 | 12 |
| Weight | 540g | 650g |
| Operating Voltage | DC12V-48V | DC12V-48V |
| Static Current | 0.09A@24V | 0.1A@24V |
| Maximum Current | 2A@24V | 2A@24V |
| Repeatability | ±0.20mm | ±0.20mm |
| Thumb Fingertip Grip Force | 15N | 15N |
| Four-Finger Fingertip Grip Force | 10N | 10N |
| Grip Force Resolution | 0.50N | 0.50N |
| Thumb Rotation Range | >65° | >65° |
| Thumb Abduction Speed | 107°/s | 107°/s |
| Thumb Flexion Speed | 70°/s | 70°/s |
| Four-Finger Flexion Speed | 260°/s | 260°/s |
| Wrist Swing Angle | / | ±27° |
| Wrist Pitch Angle | / | ±22° |
| Wrist Load Torque | / | 2 N·m (excluding hand weight) |