Introduction
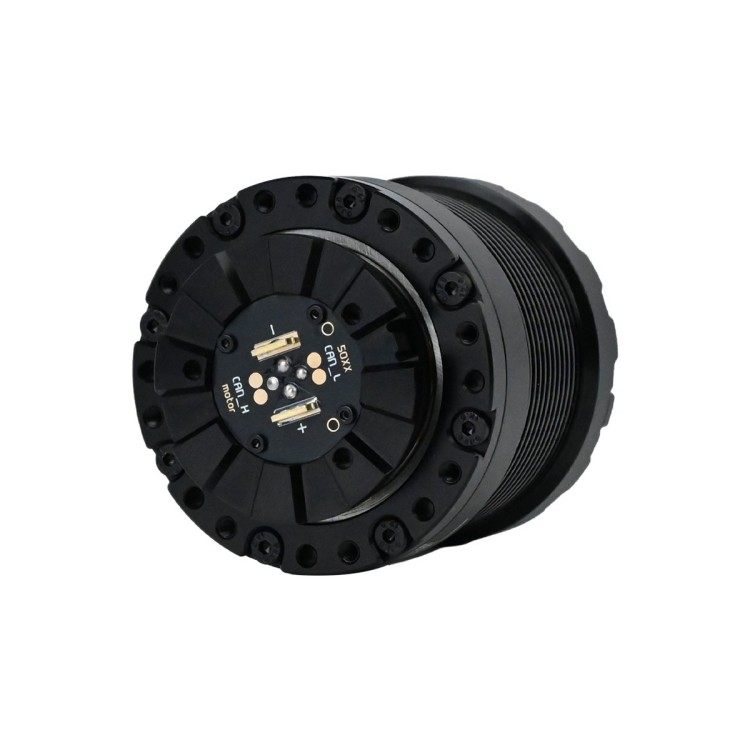
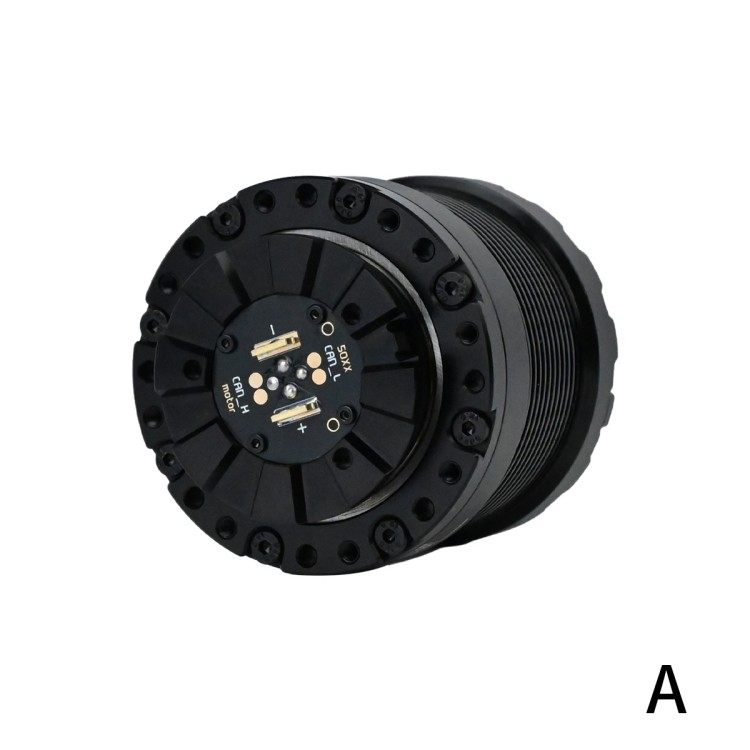
This series is the second-generation planetary joint module, featuring a high-performance inner-rotor motor specifically optimized for cogging torque and slot fill factor, delivering low torque ripple and high power density. It is paired with a two-stage planetary gear reducer; the first and second stages are independently designed and gear parameters have been refined through multiple rounds of simulation, achieving balanced load distribution and high load capacity. The module integrates a full set of self-developed power and communication interfaces, supports horizontal and vertical form factors with multiple specifications, and features a male-female locking mechanism to prevent loosening. The output and fixed ends are optimized for quick release; the rear end uses a quick-release interface, the front end is available in quick-release or non-quick-release versions, and a quick-release electrical connector is optional. The entire series adopts a hollow structure supporting internal wiring to avoid exposed cables. The motor supports multiple control modes with wide speed-control bandwidth and precise position control, and integrates over-temperature, over-voltage and overload protection. Dual encoders come as standard, with CAN/CANFD communication at 1M/5M baud rate.
Performance Parameters
Item | Value | Unit |
Rated Voltage | 72 | V |
Rated Bus Current | 7.1 | A |
Rated Input Power | 511.2 | W |
Rated Phase Current | 9.6 | A |
Rated Torque | 12 | Nm |
Allowable Continuous Torque | 11 | Nm |
Peak Phase Current | 40 | A |
Peak Speed | 340 | RPM |
Peak Torque | 50 | Nm |
Torque Constant | 1.4 | Nm/A |
Average Motor Efficiency | 70% |
|
Communication | CAN/CANFD |
|
Communication Baud Rate | 1M/5M |
|
Dual Encoder | Yes |
|
Reduction Ratio | 17 |
|
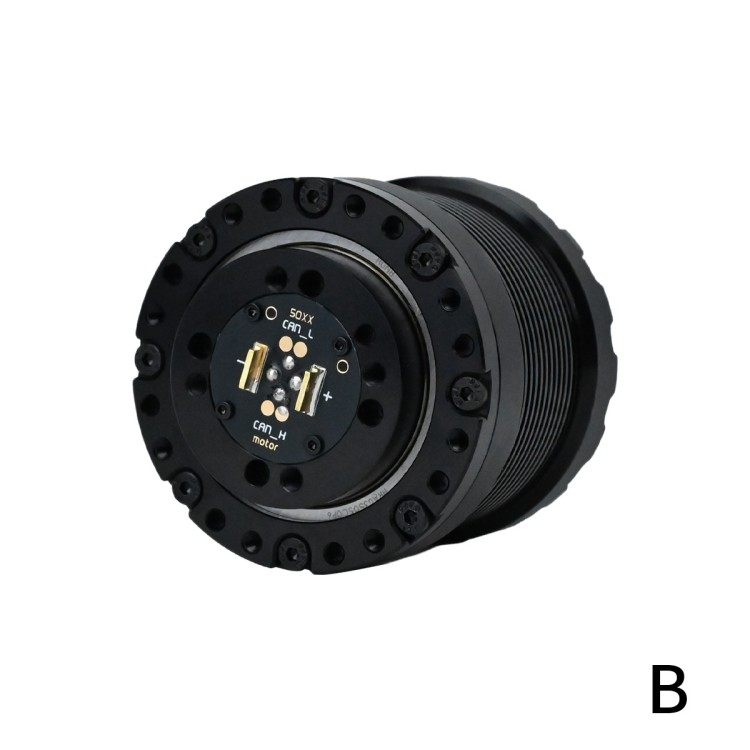
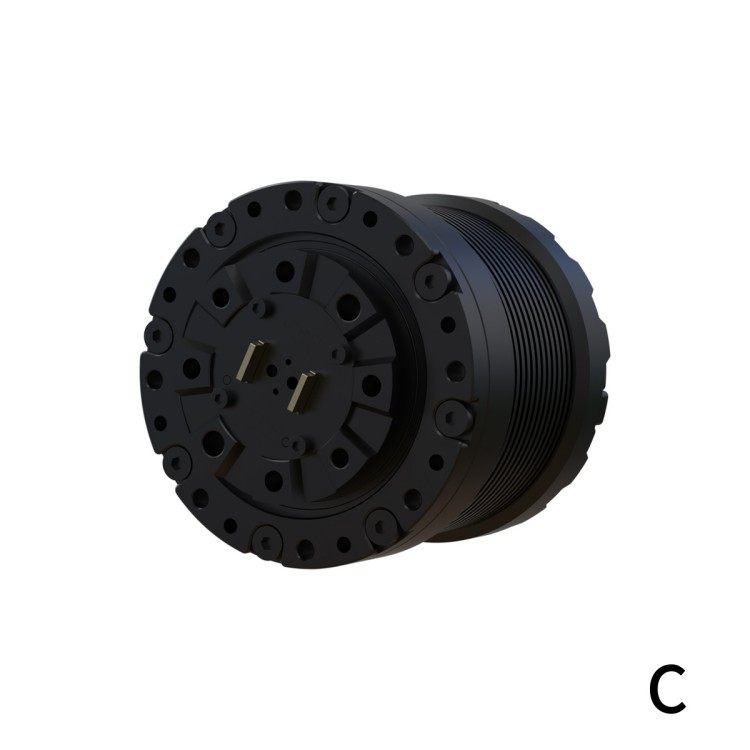
Motor Weight | 550 (Type A)/546 (Type B)/522 (Type C, est.) | g |
Gear Reducer Backlash | 18 | Arcmin |
Motor Size (OD x Thickness) | 60×77 (w/ power)/60×68.8 (w/o power) (Type A); 60×76.5/60×66.5 (Type B); 60×75.5/60×66.3 (Type C) | mm |
Hollow Bore Diameter | 4 | mm |
Axial / Radial Load | 2.2 | KN |
Bending Moment Resistance | 17 | Nm |
Crossed Roller Bearing Model | 3505 |
|
Rotor Inertia | 13 | Kg·mm² |
Measured Data - Torque Characteristics (72V)
Bus Current (A) | Input Power (W) | Torque (Nm) | Phase Current (A) | Speed (RPM) | Efficiency | Torque / Phase Current |
0.03 | 2.16 | 0.7 | 1.67 | 0 | 0 | 0.42 |
0.03 | 2.16 | 1.8 | 2.22 | 0 | 0 | 0.81 |
0.05 | 3.60 | 3.3 | 3.32 | 0 | 0 | 0.99 |
0.04 | 2.88 | 4.3 | 3.88 | 0 | 0 | 1.11 |
0.06 | 4.32 | 5.2 | 4.46 | 0 | 0 | 1.17 |
0.08 | 5.76 | 6.3 | 5.26 | 0 | 0 | 1.20 |
0.11 | 7.92 | 7.6 | 6.09 | 0 | 0 | 1.25 |
0.12 | 8.64 | 8.5 | 6.65 | 0 | 0 | 1.28 |
0.14 | 10.08 | 9.6 | 7.48 | 0 | 0 | 1.28 |
0.19 | 13.68 | 10.5 | 8.04 | 0 | 0 | 1.31 |
0.2 | 14.40 | 11.4 | 8.6 | 0 | 0 | 1.33 |
0.26 | 18.72 | 12.6 | 9.41 | 0 | 0 | 1.34 |
0.27 | 19.44 | 13.6 | 9.97 | 0 | 0 | 1.36 |
0.33 | 23.76 | 14.9 | 10.8 | 0 | 0 | 1.38 |
0.41 | 29.52 | 16.4 | 11.9 | 0 | 0 | 1.38 |
0.47 | 33.84 | 17.7 | 12.74 | 0 | 0 | 1.39 |
0.51 | 36.72 | 18.9 | 13.55 | 0 | 0 | 1.39 |
0.54 | 38.88 | 19.8 | 14.09 | 0 | 0 | 1.41 |
0.67 | 48.24 | 21.4 | 15.19 | 0 | 0 | 1.41 |
0.77 | 55.44 | 22.8 | 16.04 | 0 | 0 | 1.42 |
0.85 | 61.20 | 24.3 | 17.12 | 0 | 0 | 1.42 |
0.97 | 69.84 | 25.7 | 18.25 | 0 | 0 | 1.41 |
1.24 | 89.28 | 27.6 | 19.89 | 0 | 0 | 1.39 |
1.44 | 103.68 | 29.2 | 21.26 | 0 | 0 | 1.37 |
1.63 | 117.36 | 30.4 | 22.4 | 0 | 0 | 1.36 |
1.78 | 128.16 | 31.6 | 23.49 | 0 | 0 | 1.35 |
2.16 | 155.52 | 33.7 | 25.11 | 0 | 0 | 1.34 |
2.35 | 169.20 | 34.7 | 25.96 | 0 | 0 | 1.34 |
2.69 | 193.68 | 36.2 | 27.33 | 0 | 0 | 1.32 |
3.13 | 225.36 | 37.6 | 28.73 | 0 | 0 | 1.31 |
4.09 | 294.48 | 39.1 | 31.2 | 0 | 0 | 1.25 |
5.11 | 367.92 | 40.4 | 33.39 | 0 | 0 | 1.21 |
6.29 | 452.88 | 41.5 | 35.61 | 0 | 0 | 1.17 |
7.36 | 529.92 | 42.6 | 37.54 | 0 | 0 | 1.13 |
8.03 | 578.16 | 43.5 | 38.65 | 0 | 0 | 1.13 |
8.72 | 627.84 | 44.2 | 39.73 | 0 | 0 | 1.11 |
Measured Data - Torque-Speed (T-N) Curve (72V)
Bus Current (A) | Output Power (W) | Torque (Nm) | Speed (RPM) | Phase Current (A) | Efficiency | Torque / Phase Current |
2.11 | 67.78 | 1.9 | 340.69 | 2.21 | 45% | 0.86 |
2.5 | 106.73 | 3 | 339.76 | 2.05 | 59% | 1.46 |
3.63 | 140.68 | 4 | 335.88 | 2.54 | 54% | 1.57 |
2.51 | 173.92 | 5 | 332.18 | 1.53 | 96% | 3.27 |
6.74 | 206.40 | 6 | 328.52 | 7.24 | 43% | 0.83 |
5.58 | 251.48 | 7.4 | 324.54 | 5.69 | 63% | 1.30 |
5.98 | 283.44 | 8.4 | 322.24 | 5.35 | 66% | 1.57 |
6.94 | 329.65 | 9.9 | 318 | 7.49 | 66% | 1.32 |
7.79 | 373.48 | 11.4 | 312.87 | 7.14 | 67% | 1.60 |
8.33 | 406.74 | 12.6 | 308.28 | 10.43 | 68% | 1.21 |
8.97 | 440.13 | 13.8 | 304.58 | 9.47 | 68% | 1.46 |
9.38 | 469.20 | 14.9 | 300.73 | 11.13 | 69% | 1.34 |
10.37 | 504.21 | 16.3 | 295.41 | 12.21 | 68% | 1.33 |
10.9 | 540.47 | 17.8 | 289.97 | 13.57 | 69% | 1.31 |
10.82 | 574.91 | 19.2 | 285.96 | 14.19 | 74% | 1.35 |
12.15 | 605.42 | 20.7 | 279.31 | 16.24 | 69% | 1.27 |
12.98 | 640.90 | 22.4 | 273.24 | 16.68 | 69% | 1.34 |
13.51 | 661.79 | 23.6 | 267.8 | 17.39 | 68% | 1.36 |
14.42 | 684.14 | 24.9 | 262.39 | 21.36 | 66% | 1.17 |
14.7 | 710.51 | 26.5 | 256.05 | 21.25 | 67% | 1.25 |
15.86 | 726.99 | 27.7 | 250.64 | 23.21 | 64% | 1.19 |
16.27 | 743.20 | 28.9 | 245.59 | 23.93 | 63% | 1.21 |
16.63 | 765.98 | 30.4 | 240.63 | 24.57 | 64% | 1.24 |
17.88 | 778.03 | 31.5 | 235.88 | 26.82 | 60% | 1.17 |
17.44 | 792.94 | 32.9 | 230.17 | 27.03 | 63% | 1.22 |
19.19 | 806.87 | 34.4 | 224 | 32.3 | 58% | 1.07 |
19.85 | 819.76 | 35.8 | 218.68 | 31.21 | 57% | 1.15 |
20.8 | 832.97 | 37.5 | 212.13 | 31.18 | 56% | 1.20 |
21.48 | 837.27 | 38.8 | 206.08 | 37.73 | 54% | 1.03 |
21.93 | 838.16 | 40 | 200.11 | 35.39 | 53% | 1.13 |
22.27 | 833.94 | 40.8 | 195.2 | 39.1 | 52% | 1.04 |
23.01 | 815.25 | 41.8 | 186.26 | 40.83 | 49% | 1.02 |
21.9 | 766.90 | 42.9 | 170.72 | 40.13 | 49% | 1.07 |
8.16 | 0.00 | 43.9 | 0 | 39.99 | 0% | 1.10 |
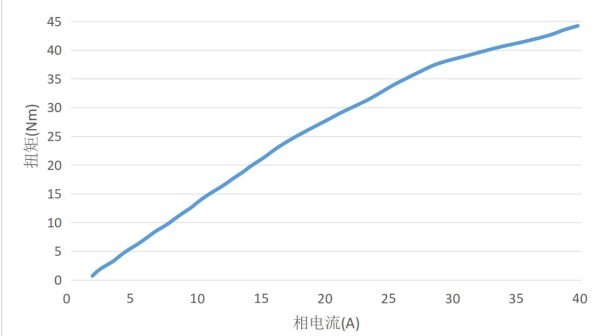
Motor Torque Characteristics Curve
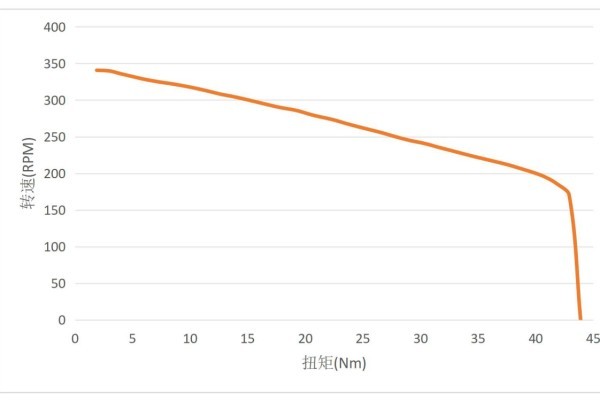
Motor T-N Curve