ABOUT
Category
Detail
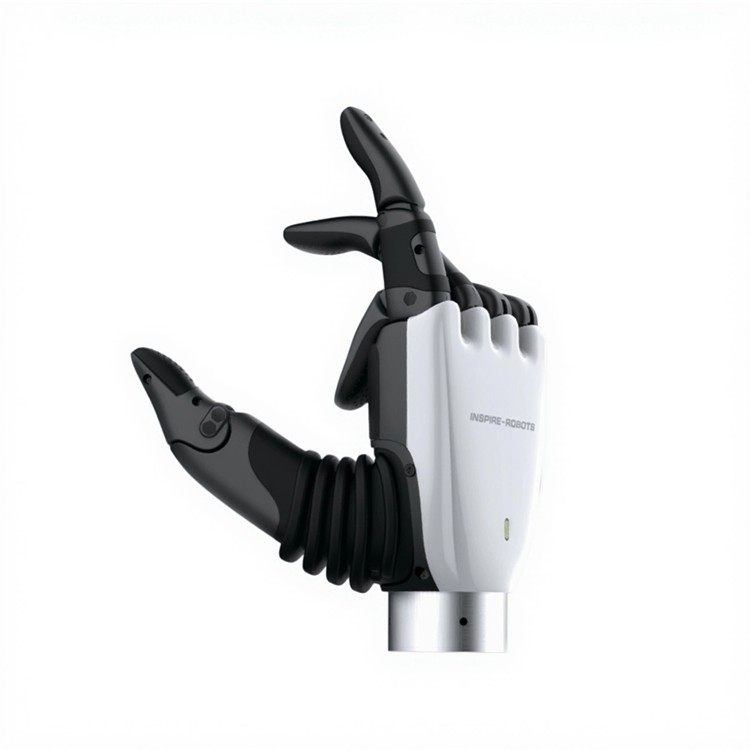
| RH56H1 Series · Humanoid Five-Finger Dexterous Hand | ||
| Tactile Version (T2) | ||
| Parameter | RH56H1-42R-T2 (Right-hand model) RH56H1-42L-T2 (Left-hand model) | RH56H1-E6R-T2 (Right-hand model) RH56H1-E6L-T2 (Left-hand model) |
| Control Interface | RS485+CANFD | EtherCAT+CAN-FD+RS485 |
| Degrees of Freedom (DOF) | 6 | 6 |
| Number of Joints | 11 | 11 |
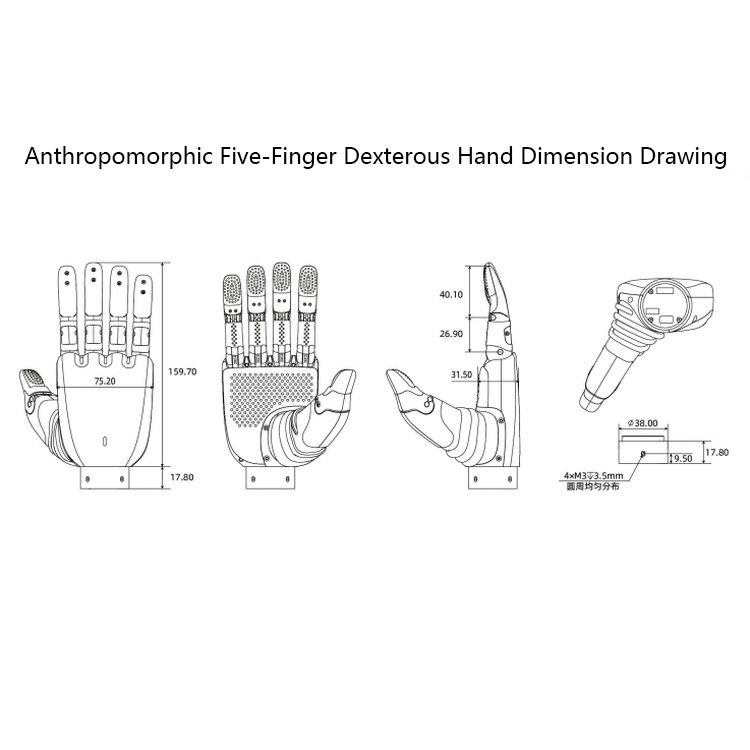
| Weight | 470±10g | 470±10g |
| Operating Voltage | 24V~60V | 24V~60V |
| Static Current | 160mA±20mA@24V | 160mA±20mA@24V |
| Maximum Current | 5A @24V | 5A @24V |
| Fingertip Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Grip Force | ≥15N | ≥15N |
| Four-Finger Fingertip Grip Force | ≥10N | ≥10N |
| Grip Force Resolution | 0.1N | 0.1N |
| Thumb Abduction Range | 70~170° | 70~170° |
| Thumb Abduction Speed | >157°/s | >157°/s |
| Thumb Flexion Speed | >65°/s | >65°/s |
| Four-Finger Flexion Speed | >110°/s | >110°/s |
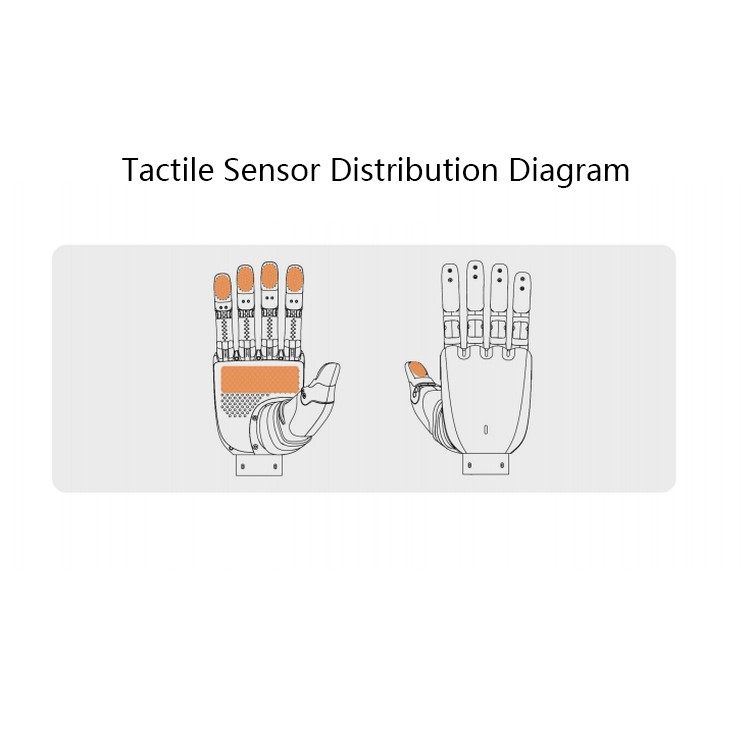
| Tactile Sensor Range | 30N | 30N |
| Tactile Sensor Accuracy | 5%FS | 5%FS |
| Number of Tactile Sensors | 6 | 6 |
| Palm Closing Time | ≤0.8s | ≤0.8s |
| Standard Version (No Tactile) | ||
| Parameter | RH56H1-42R (Right-hand model) | RH56H1-42L (Left-hand model) |
| Control Interface | RS485+CANFD | RS485+CANFD |
| Degrees of Freedom (DOF) | 6 | 6 |
| Number of Joints | 11 | 11 |
| Weight | 470±10g | 470±10g |
| Operating Voltage | 24V~60V | 24V~60V |
| Static Current | 160mA±20mA@24V | 160mA±20mA@24V |
| Maximum Current | 5A @24V | 5A @24V |
| Fingertip Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Grip Force | ≥15N | ≥15N |
| Four-Finger Fingertip Grip Force | ≥10N | ≥10N |
| Grip Force Resolution | 0.1N | 0.1N |
| Thumb Abduction Range | 70~170° | 70~170° |
| Thumb Abduction Speed | >157°/s | >157°/s |
| Thumb Flexion Speed | >65°/s | >65°/s |
| Four-Finger Flexion Speed | >110°/s | >110°/s |
| Tactile Sensor Range | / | / |
| Tactile Sensor Accuracy | / | / |
| Number of Tactile Sensors | / | / |
| Palm Closing Time | ≤0.8s | ≤0.8s |
Download
{item.title}
预览
下载
Previous:RH56F1
Next:Copper Hammer M1
Inquiry