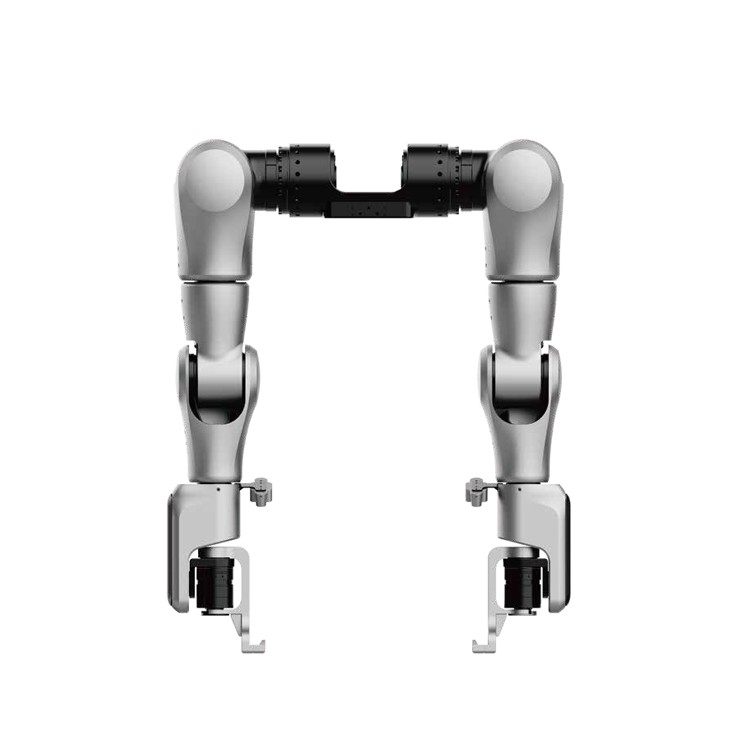
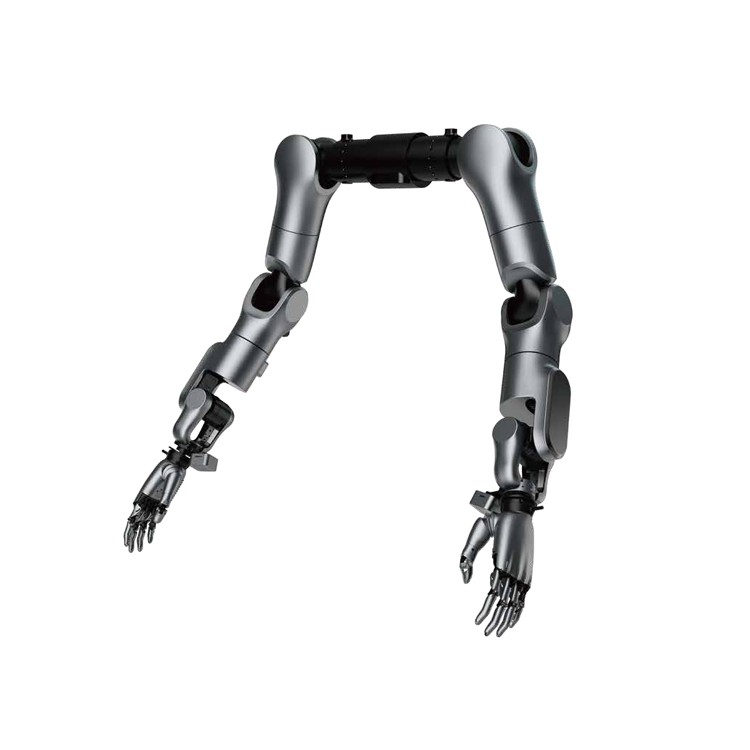
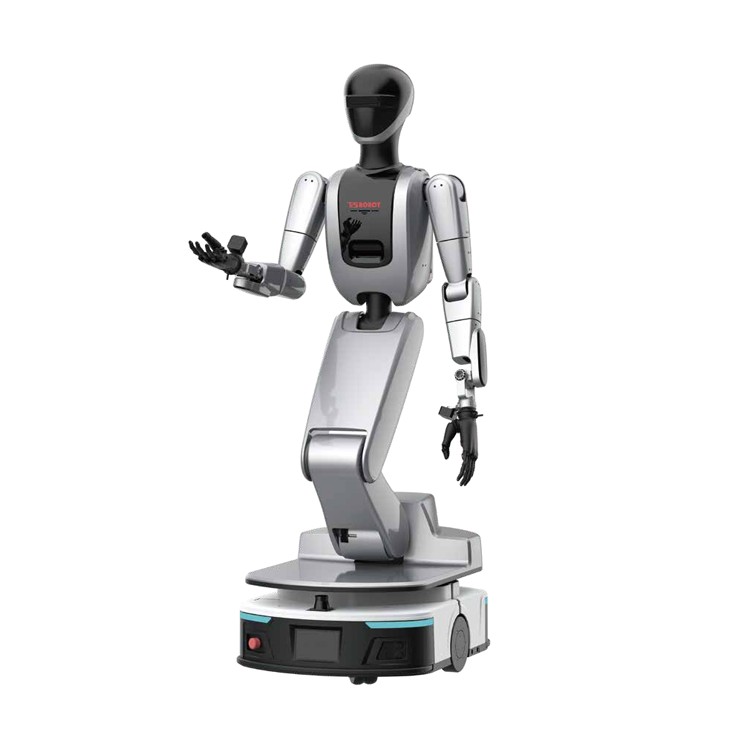
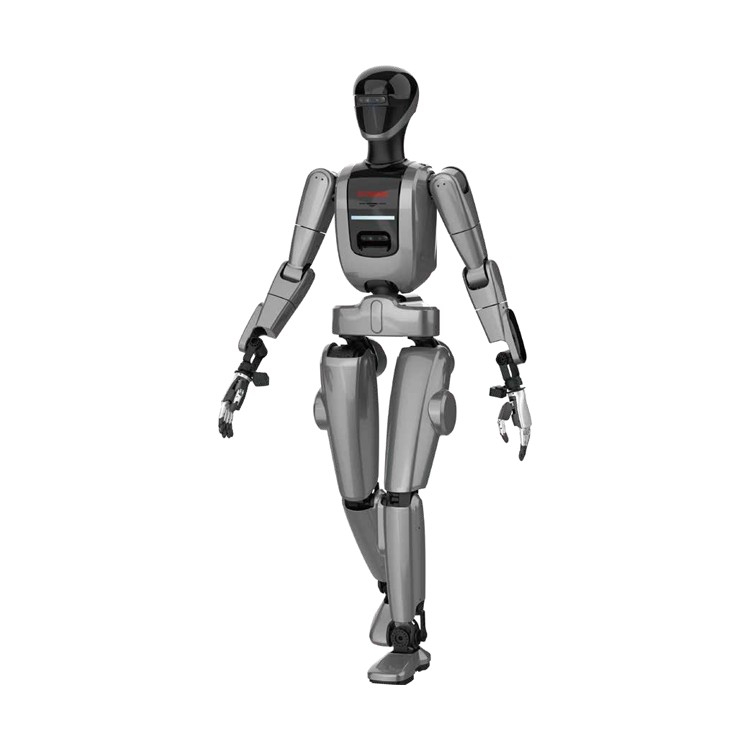
| Model | Ti5-A10-1 Dual-Arm Standard Product |
| Max arm circumference | 160mm |
| Arm span | 2013mm |
| Total weight | 32kg |
| Structural component layout | Internal structural components |
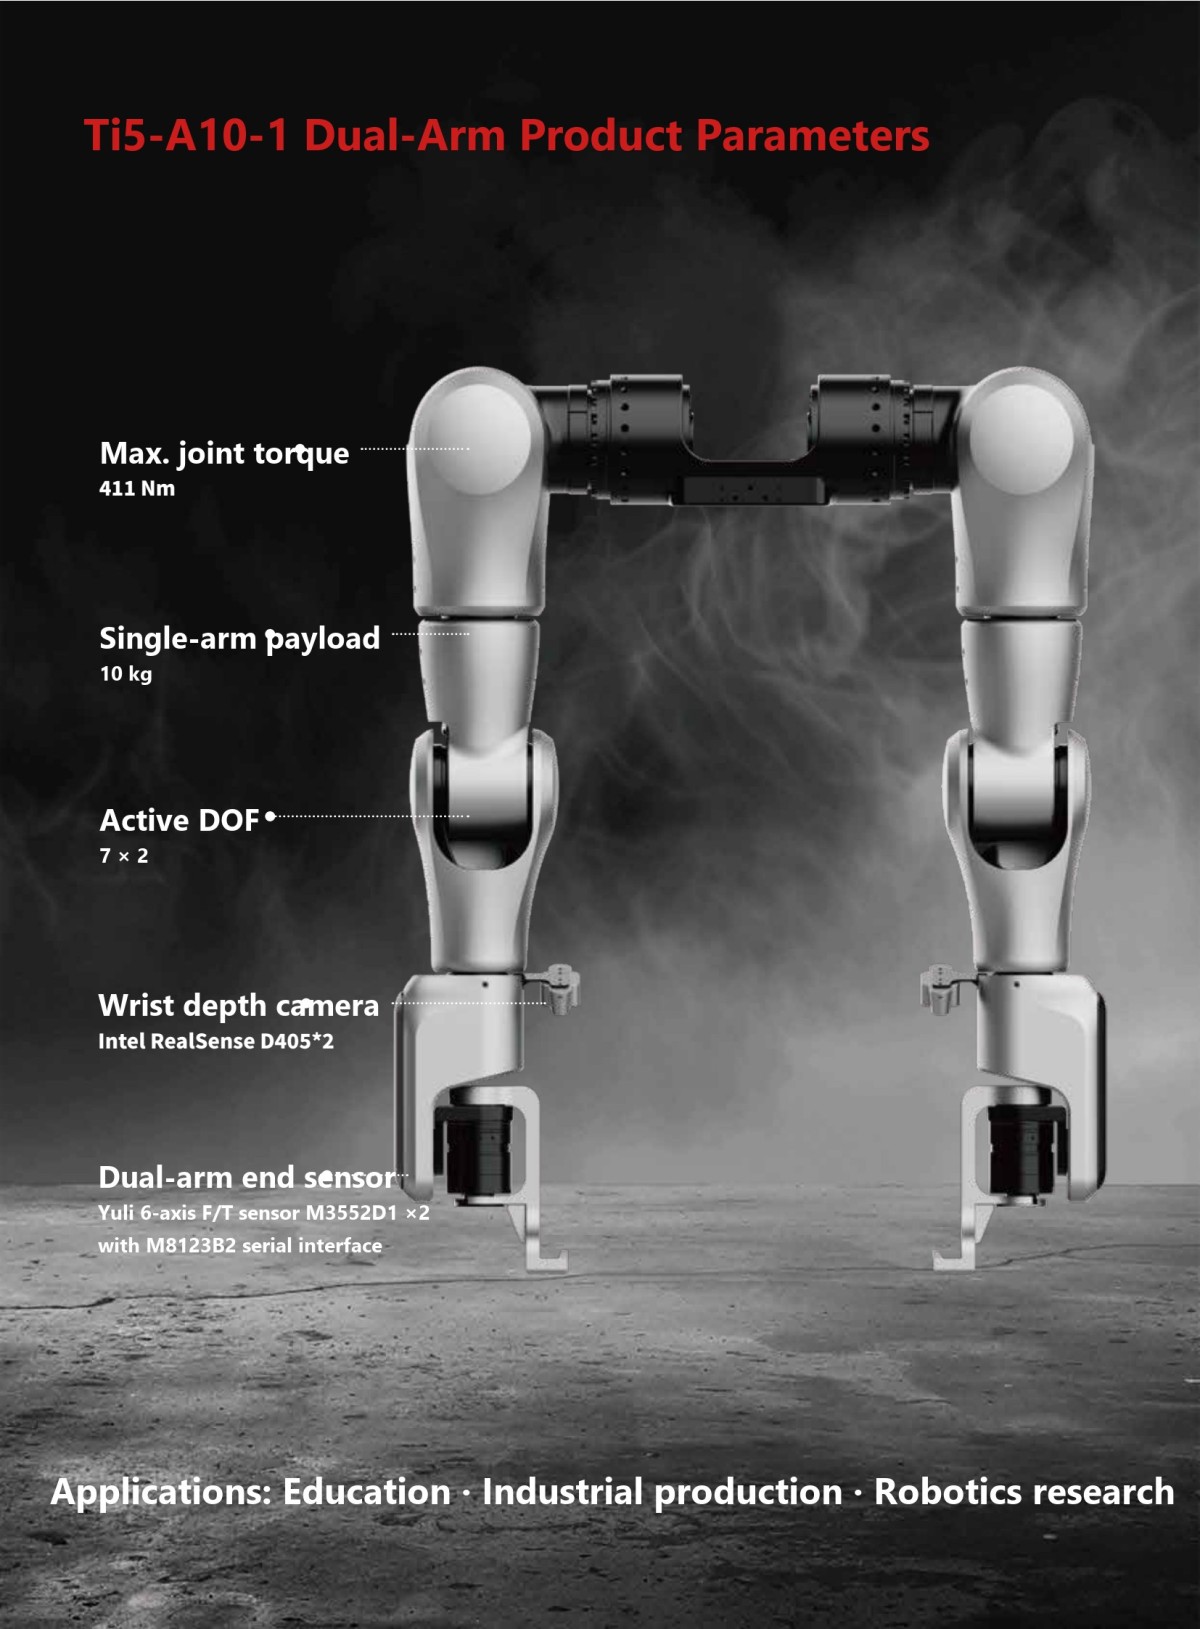
| Single-arm payload | 10kg |
| Total DOF | 14 |
| Single-arm DOF | 7 |
| Hand gripper | Universal spherical gripper/hook gripper |
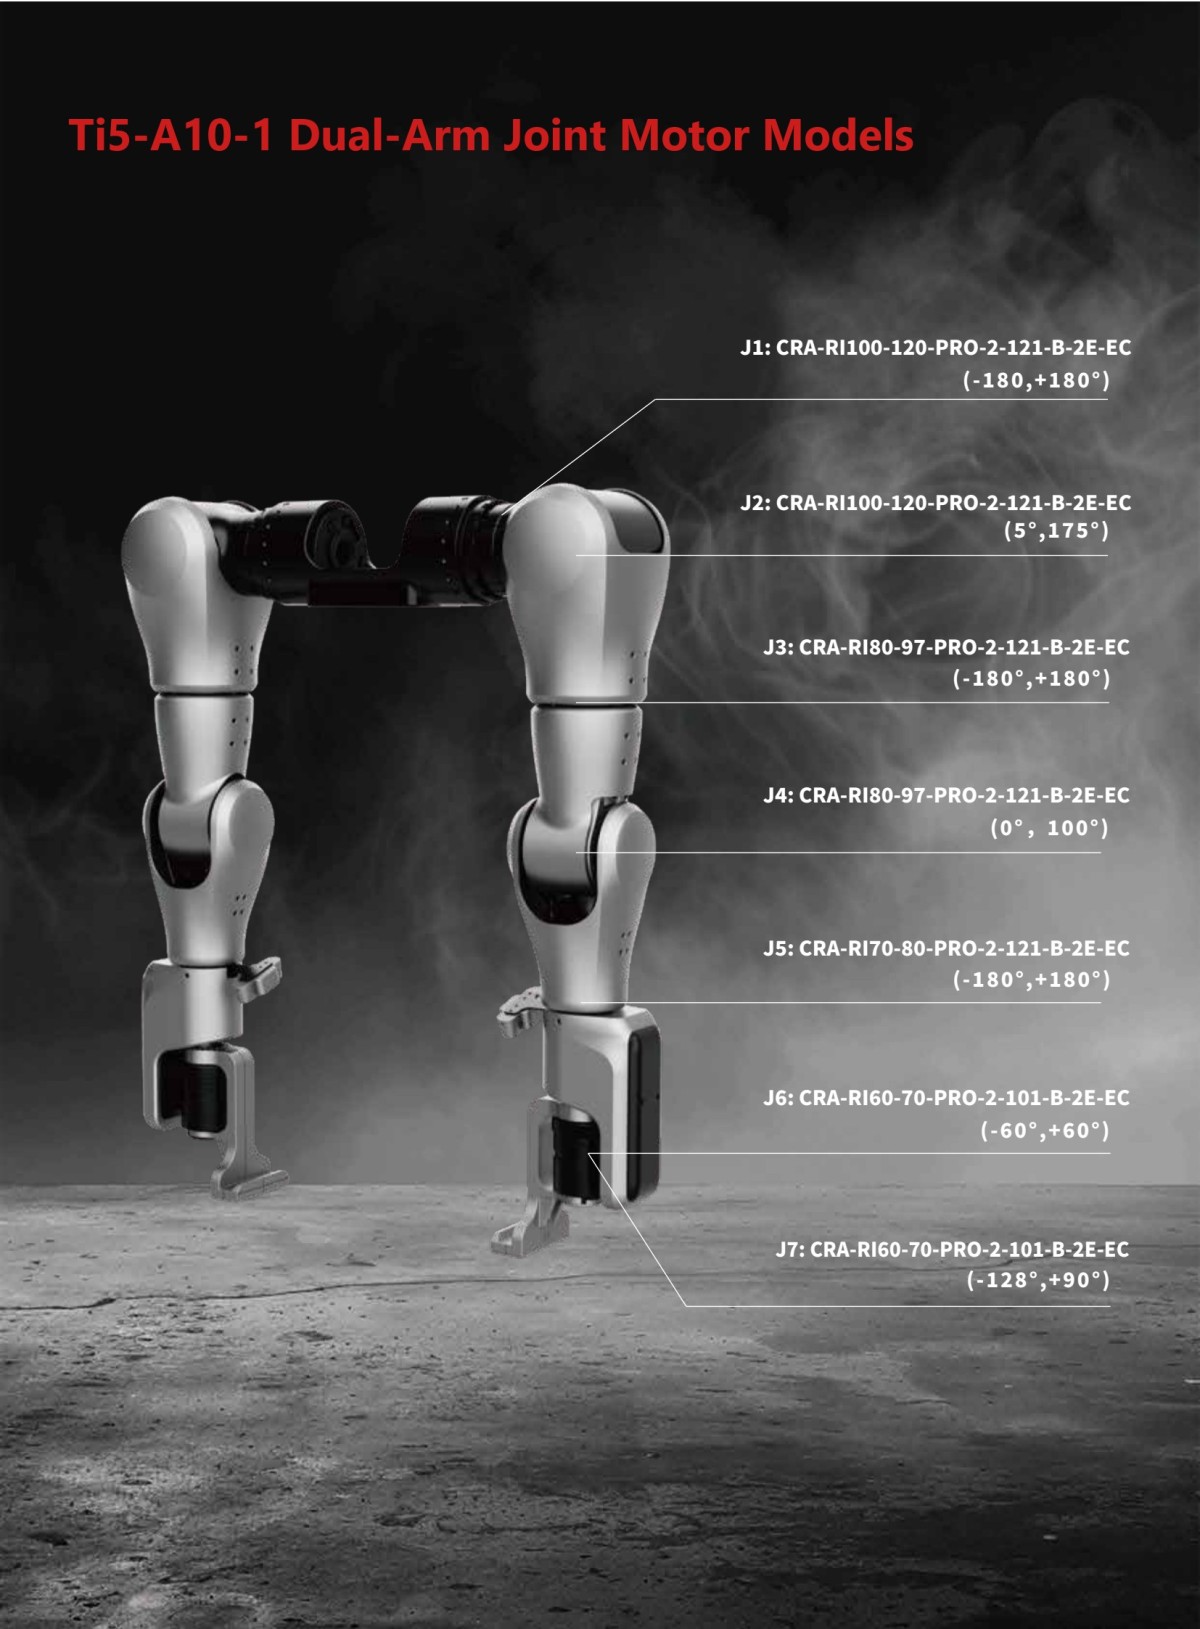
| Number of joint motors | 14 |
| Max joint torque | Max single joint: 411 Nm |
| Joint actuator type | CAN/EtherCAT |
| Joint reducer type | Harmonic |
| Joint encoder resolution | 18bit |
| Dual-arm end sensor (optional) | Six-axis force*2 Model: SRI M3552D1 with M8123B2, 232 communication interface |
| Battery capacity (optional) | 48V 10Ah |
| Endurance | 3h |
| Vision perception (optional) | Wrist depth camera Intel RealSense D405*2 |
| Communication protocol | Joint CAN/EC, hand 485/CAN |
| Communication interface | Ethernet |
| Control and computing (optional) | Jeston Orin Nano 8G*1 (upgradable to Jeston AGX Orin 64G developer kit, optional) |
| Structural material | Aluminum alloy, stainless steel, etc. |
| Shell material | Aluminum alloy, ABS+fiberglass, rubber, etc. |
| Structure-related | URDF standard format document (output after contract signing and before complete machine delivery) |