ABOUT
Category
Detail
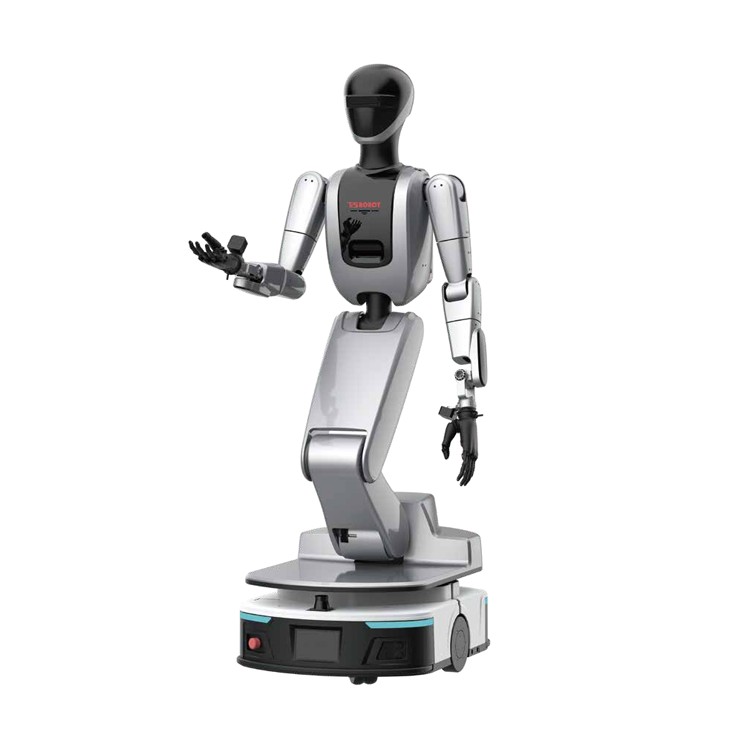
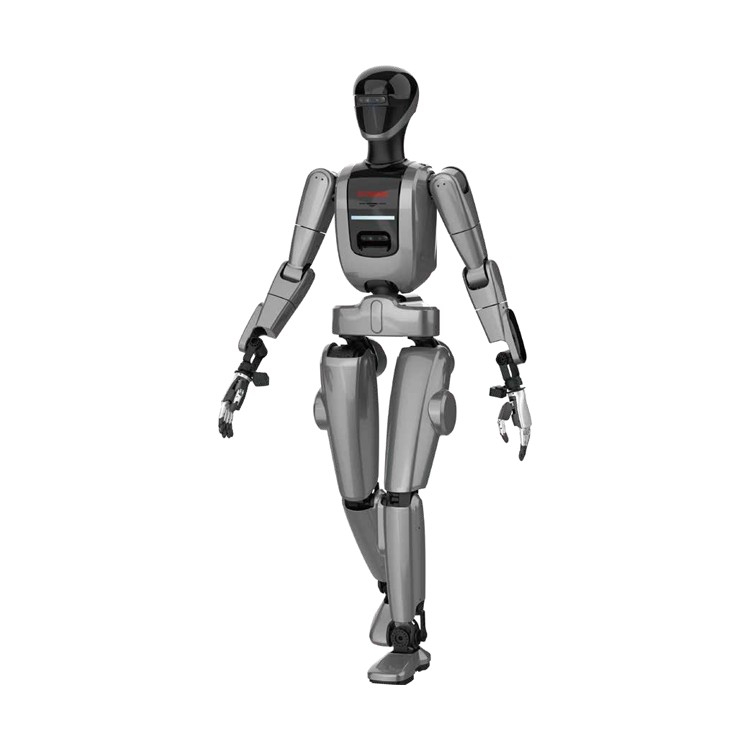
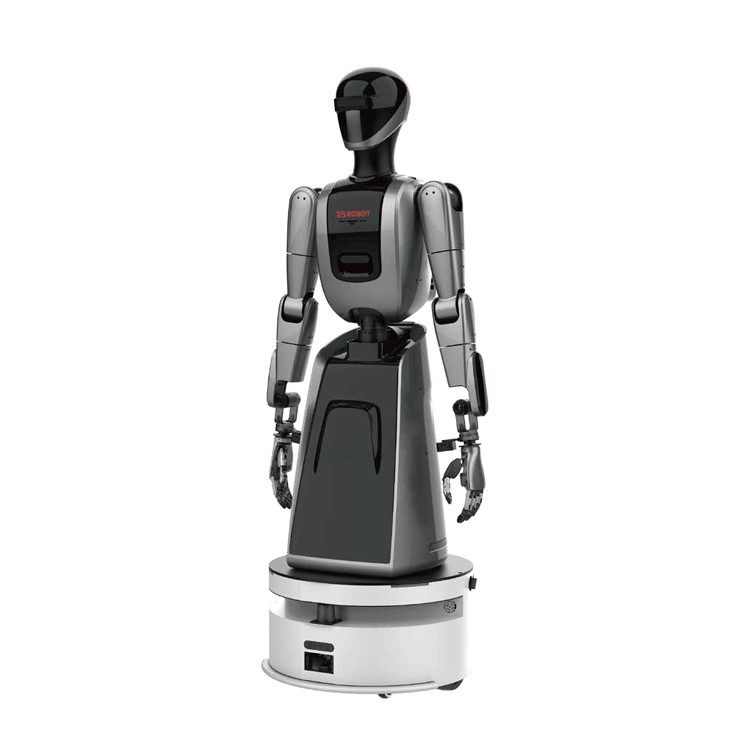
| Model | T170D Standard | 170D Flagship |
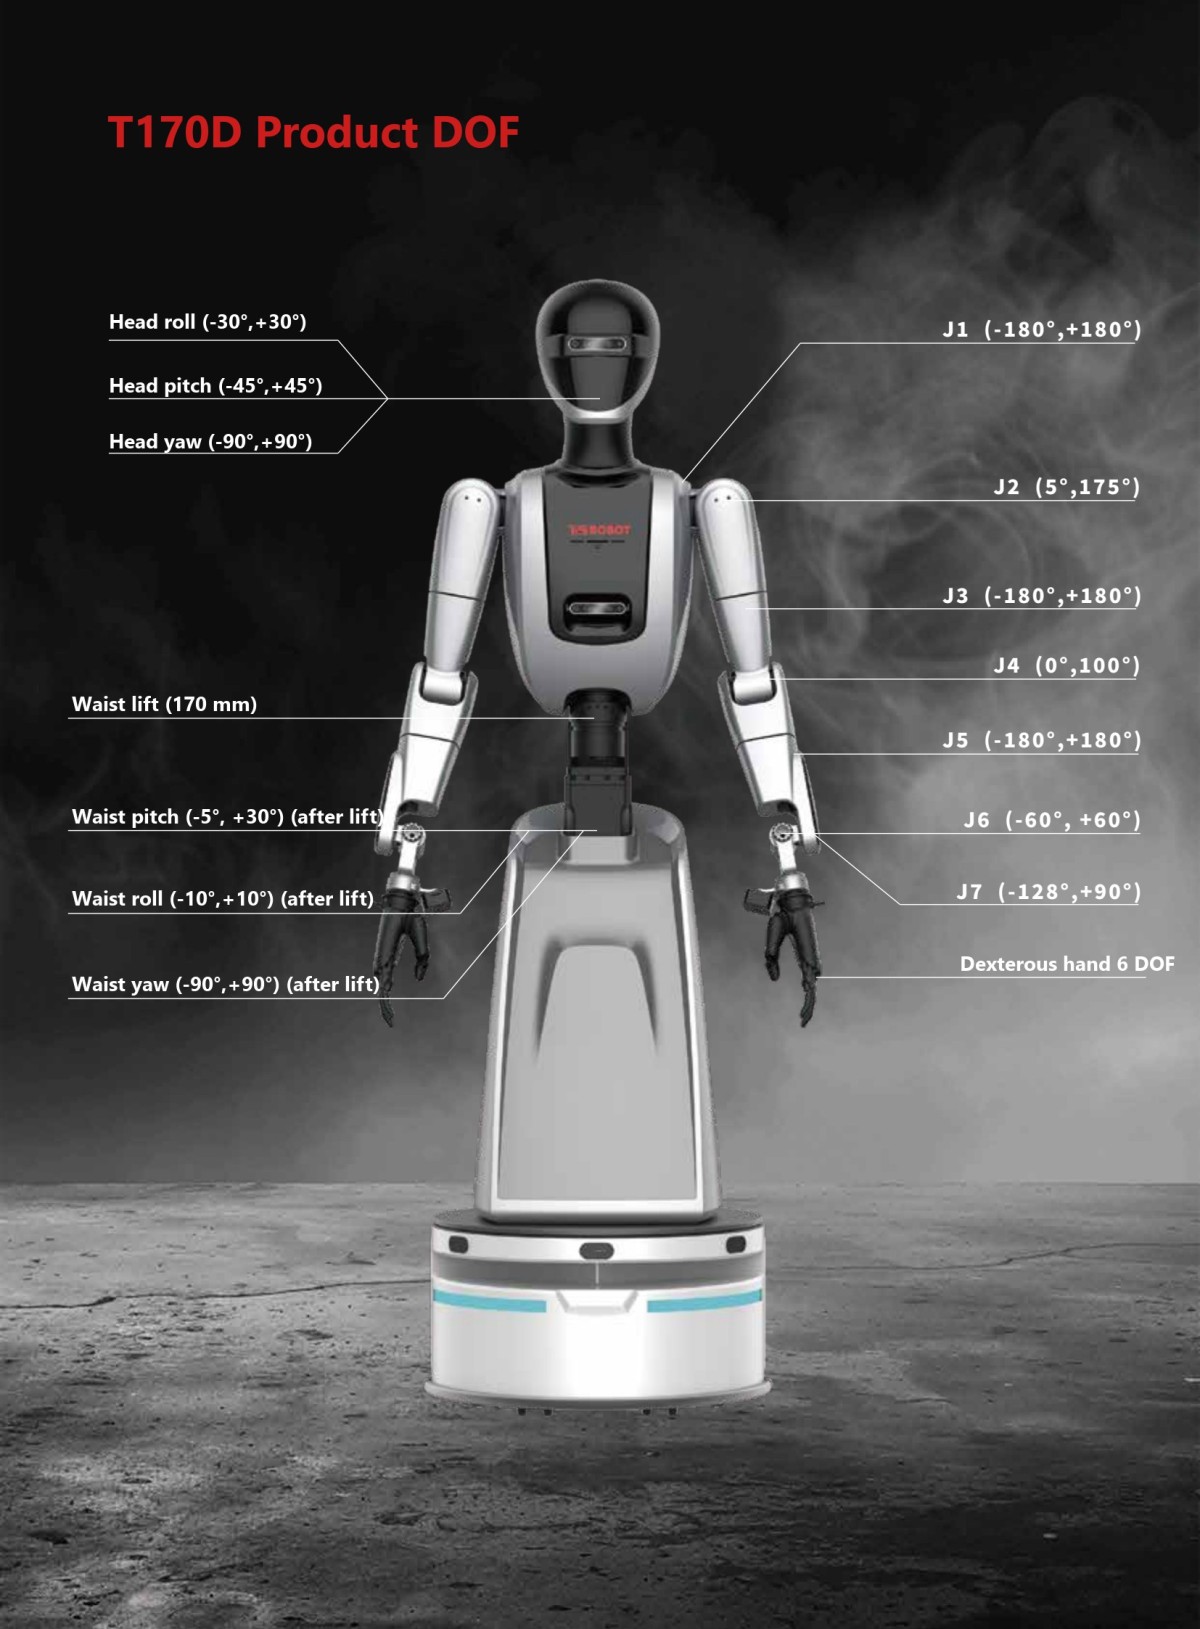
| Overall height | 1.5m+16cm lifting | 1.5M+16cm lifting |
| Total weight | 96kg | 96kg |
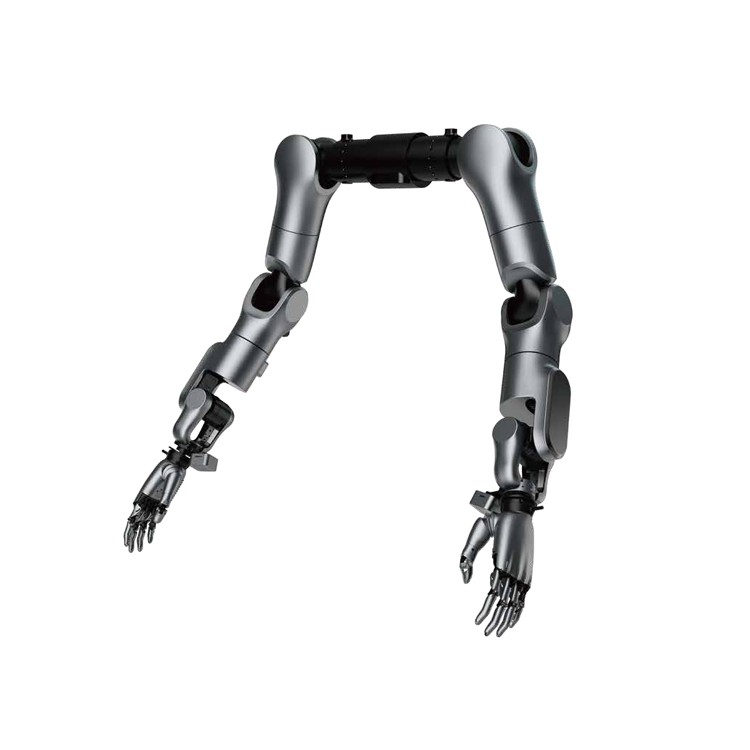
| Arm span | 1.5m | 1.5m |
| Total active DOF | 21 | 21 |
| Single-arm payload | 3/5kg | 3/5kg |
| End repeatability | ≤0.3mm | ≤0.3mm |
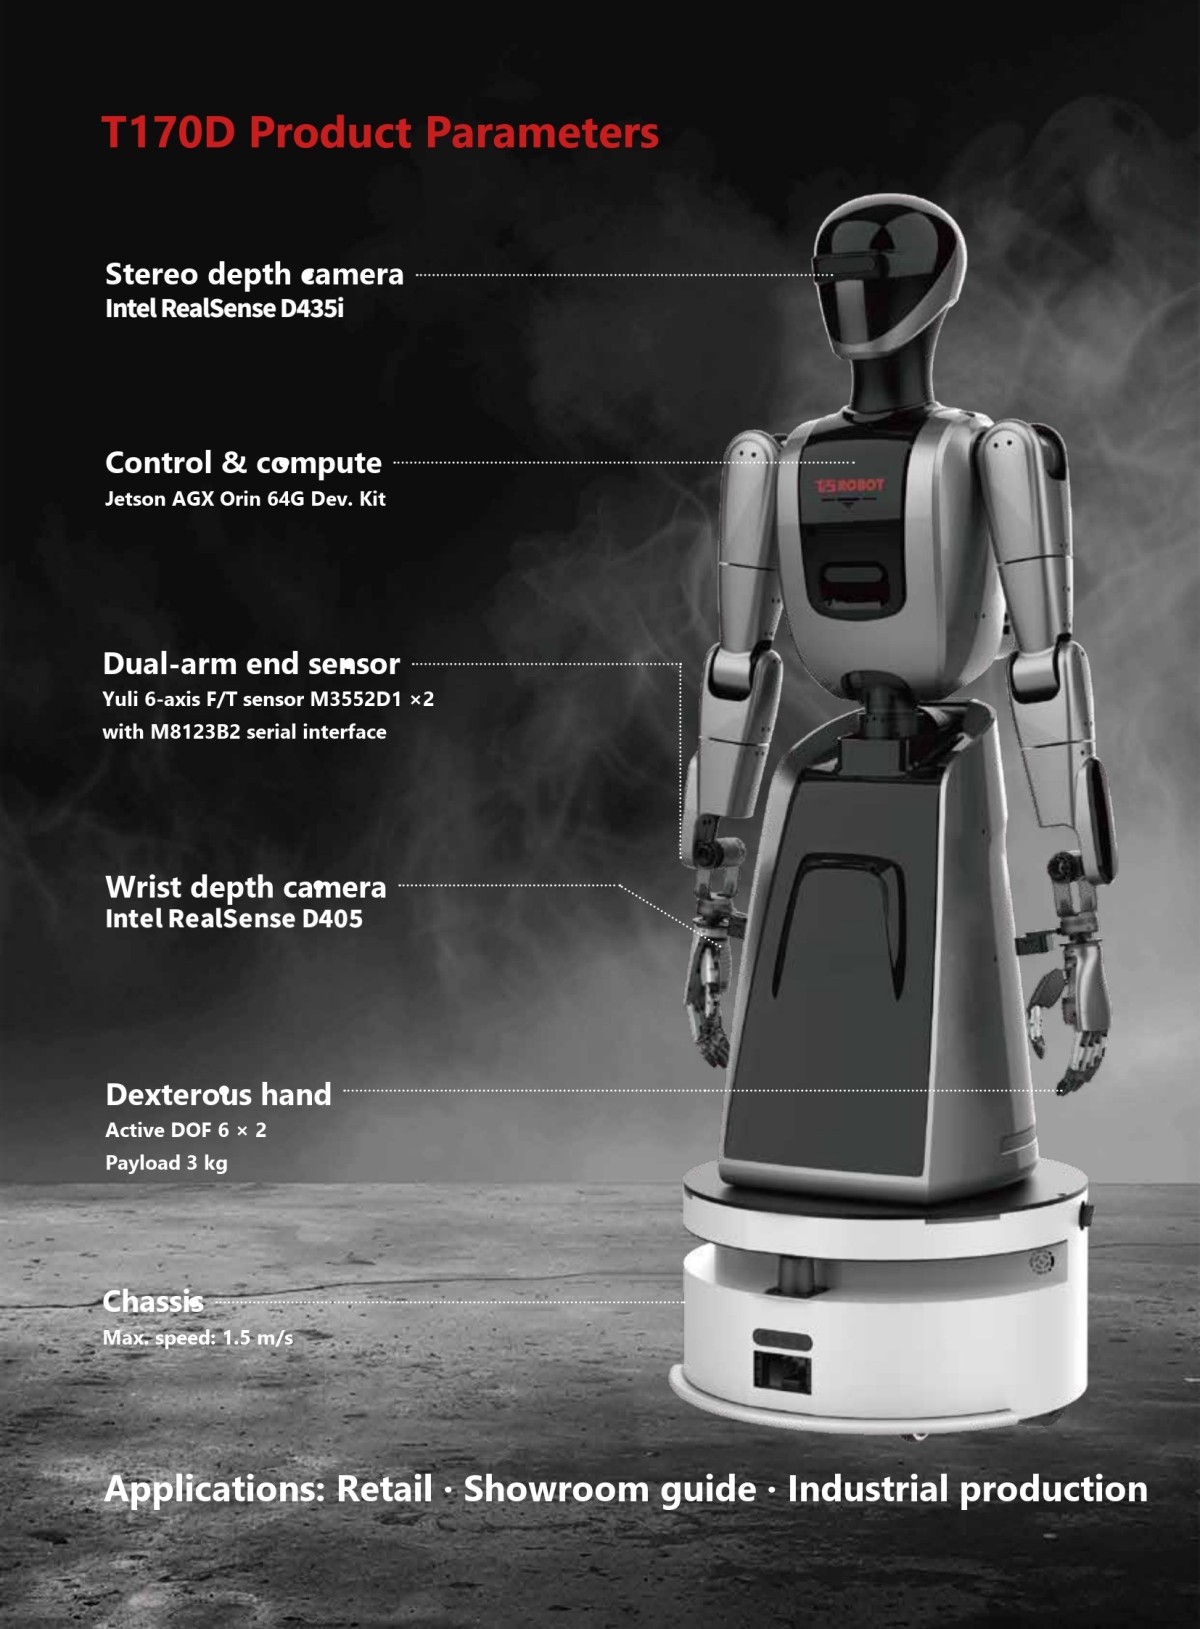
| Dexterous hand active DOF | 6 | 6 |
| Hand payload | 0.5kg | 2-3kg |
| Dexterous hand model | TH-RH-1-L/R | High-precision dexterous hand |
| Joint actuator type | CAN and EC | CAN and EC |
| Joint reducer type | Harmonic | Harmonic |
| Joint encoder resolution | 18bit | 18bit |
| Joint sensor type | / | Six-axis force*2 |
| Chassis | High-performance wheeled | High-performance wheeled |
| Chassis mobility | Max navigation speed 1.5 m/s | Max navigation speed 1.5 m/s |
| Number and types of input/output ports | USB, Ethernet port, charging port, type-c | USB, Ethernet port, charging port, type-c |
| Software algorithm | Dual-arm API | Dual-arm API |
| Materials | Structure: aluminum alloy, etc. Shell: ABS, etc. | Structure: aluminum alloy, etc. Shell: ABS, etc. |
| Vision perception | Head Intel RealSense D435i*1 | Head Intel RealSense D435i*1 Wrist Intel RealSense D405*2 |
| Control and computing | Jeston Orin Nano 8G*1 | Jeston AGX Orin 64G developer kit ARM platform |
| Communication protocol | Joint CAN and EC, hand 485 | Joint CAN and EC, hand 485 |
Download
{item.title}
预览
下载
Previous:T170A_V2
Next:T230C
Inquiry